IEO Tech|Auto
IEO Science and Technology
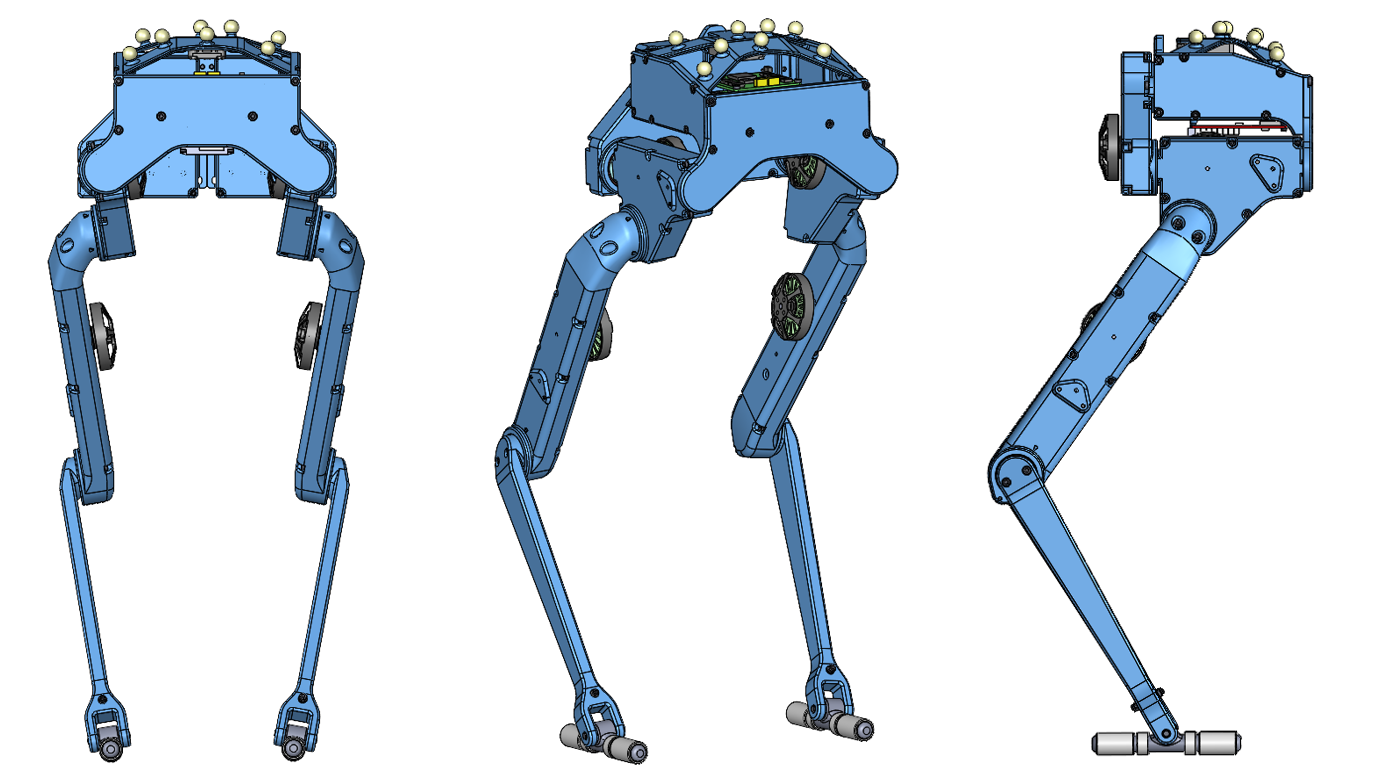
ieoBot 3D modeling development process
ieoBot bipedal jumping simulation
ieoBot standing-up video of the bipedal 8-DOF legged robot
Bolt motion control video of the bipedal 6-DOF legged robot
ieoBot bipedal 6-DOF legged robot
Product Introduction
ieoBot robot hardware:
Height approx. 550mm (excluding the optional stereo camera).
Weight approx. 1.5KG (excluding the battery).
Each leg has 3 active degrees of freedom and one passive ankle joint.
Brushless DC motors with FOC control, CAN/SPI communication and a 1KHz motor control frequency
Ten-dimensional sensor that predicts the robot's posture, velocity, falls and more
ieoBot robot software system:
HZD hybrid zero dynamics technology
RIEKF prediction algorithm
Human-like dynamic stabilization algorithm
Bare robot + motion control systemBuy now
Pre-order contact: hzf@ieeoo.com
Order lead time: 20 days
Documentation:ieoBot bipedal 6-DOF robot documentation v1